
Project Overview
This project develops a robot car controlled through the Sony SIRC infrared remote-control protocol.
The documented design receives encoded commands from a remote, decodes the expected byte stream with a microcontroller and uses the decoded commands to control robot-car movement such as forward, reverse and stop.
How the System Works
- A Sony-compatible remote transmits the selected control command.
- The robot-mounted infrared receiver captures the transmitted signal.
- The microcontroller decodes the received protocol information.
- Recognised commands are translated into movement actions for the robot car.
- The control system can command forward, reverse, stop and continuous-drive operation.
System Architecture
◆Sony RemoteSIRC command source
→
◆IR ReceiverCommand reception
→
◆MicrocontrollerProtocol decoding
→
◆Motor ControlMovement commands
→
◆Robot CarPhysical motion
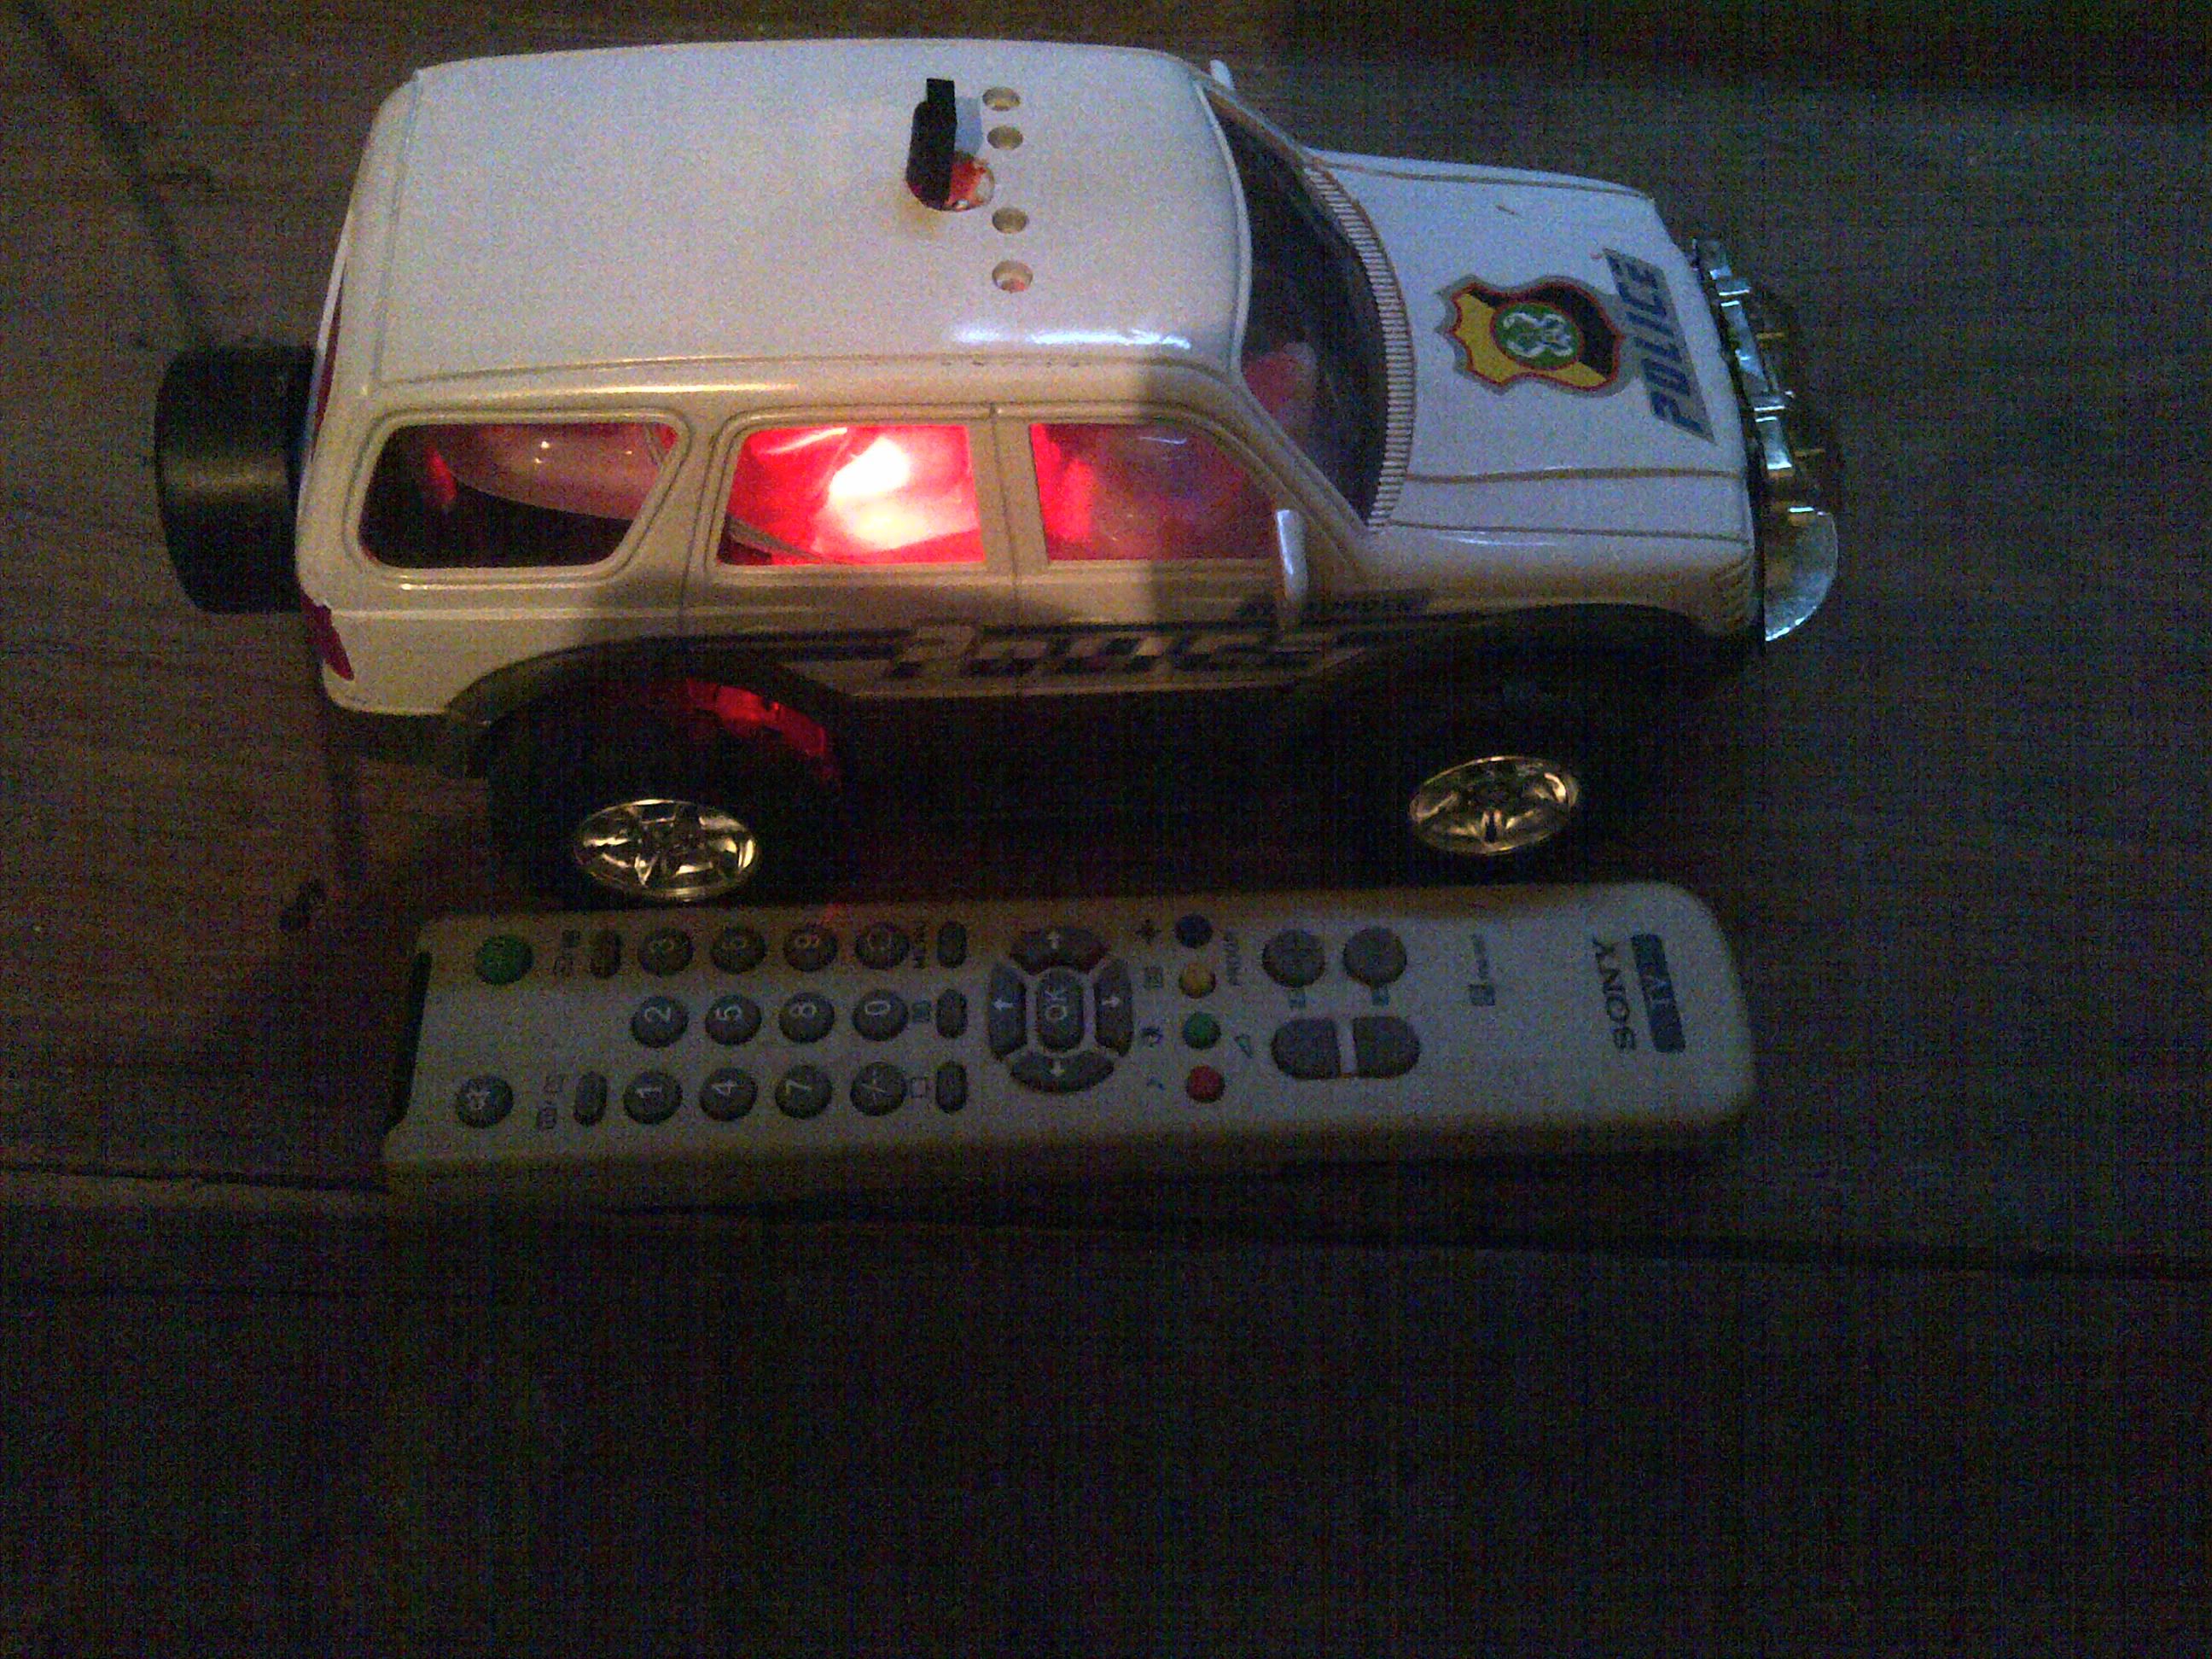
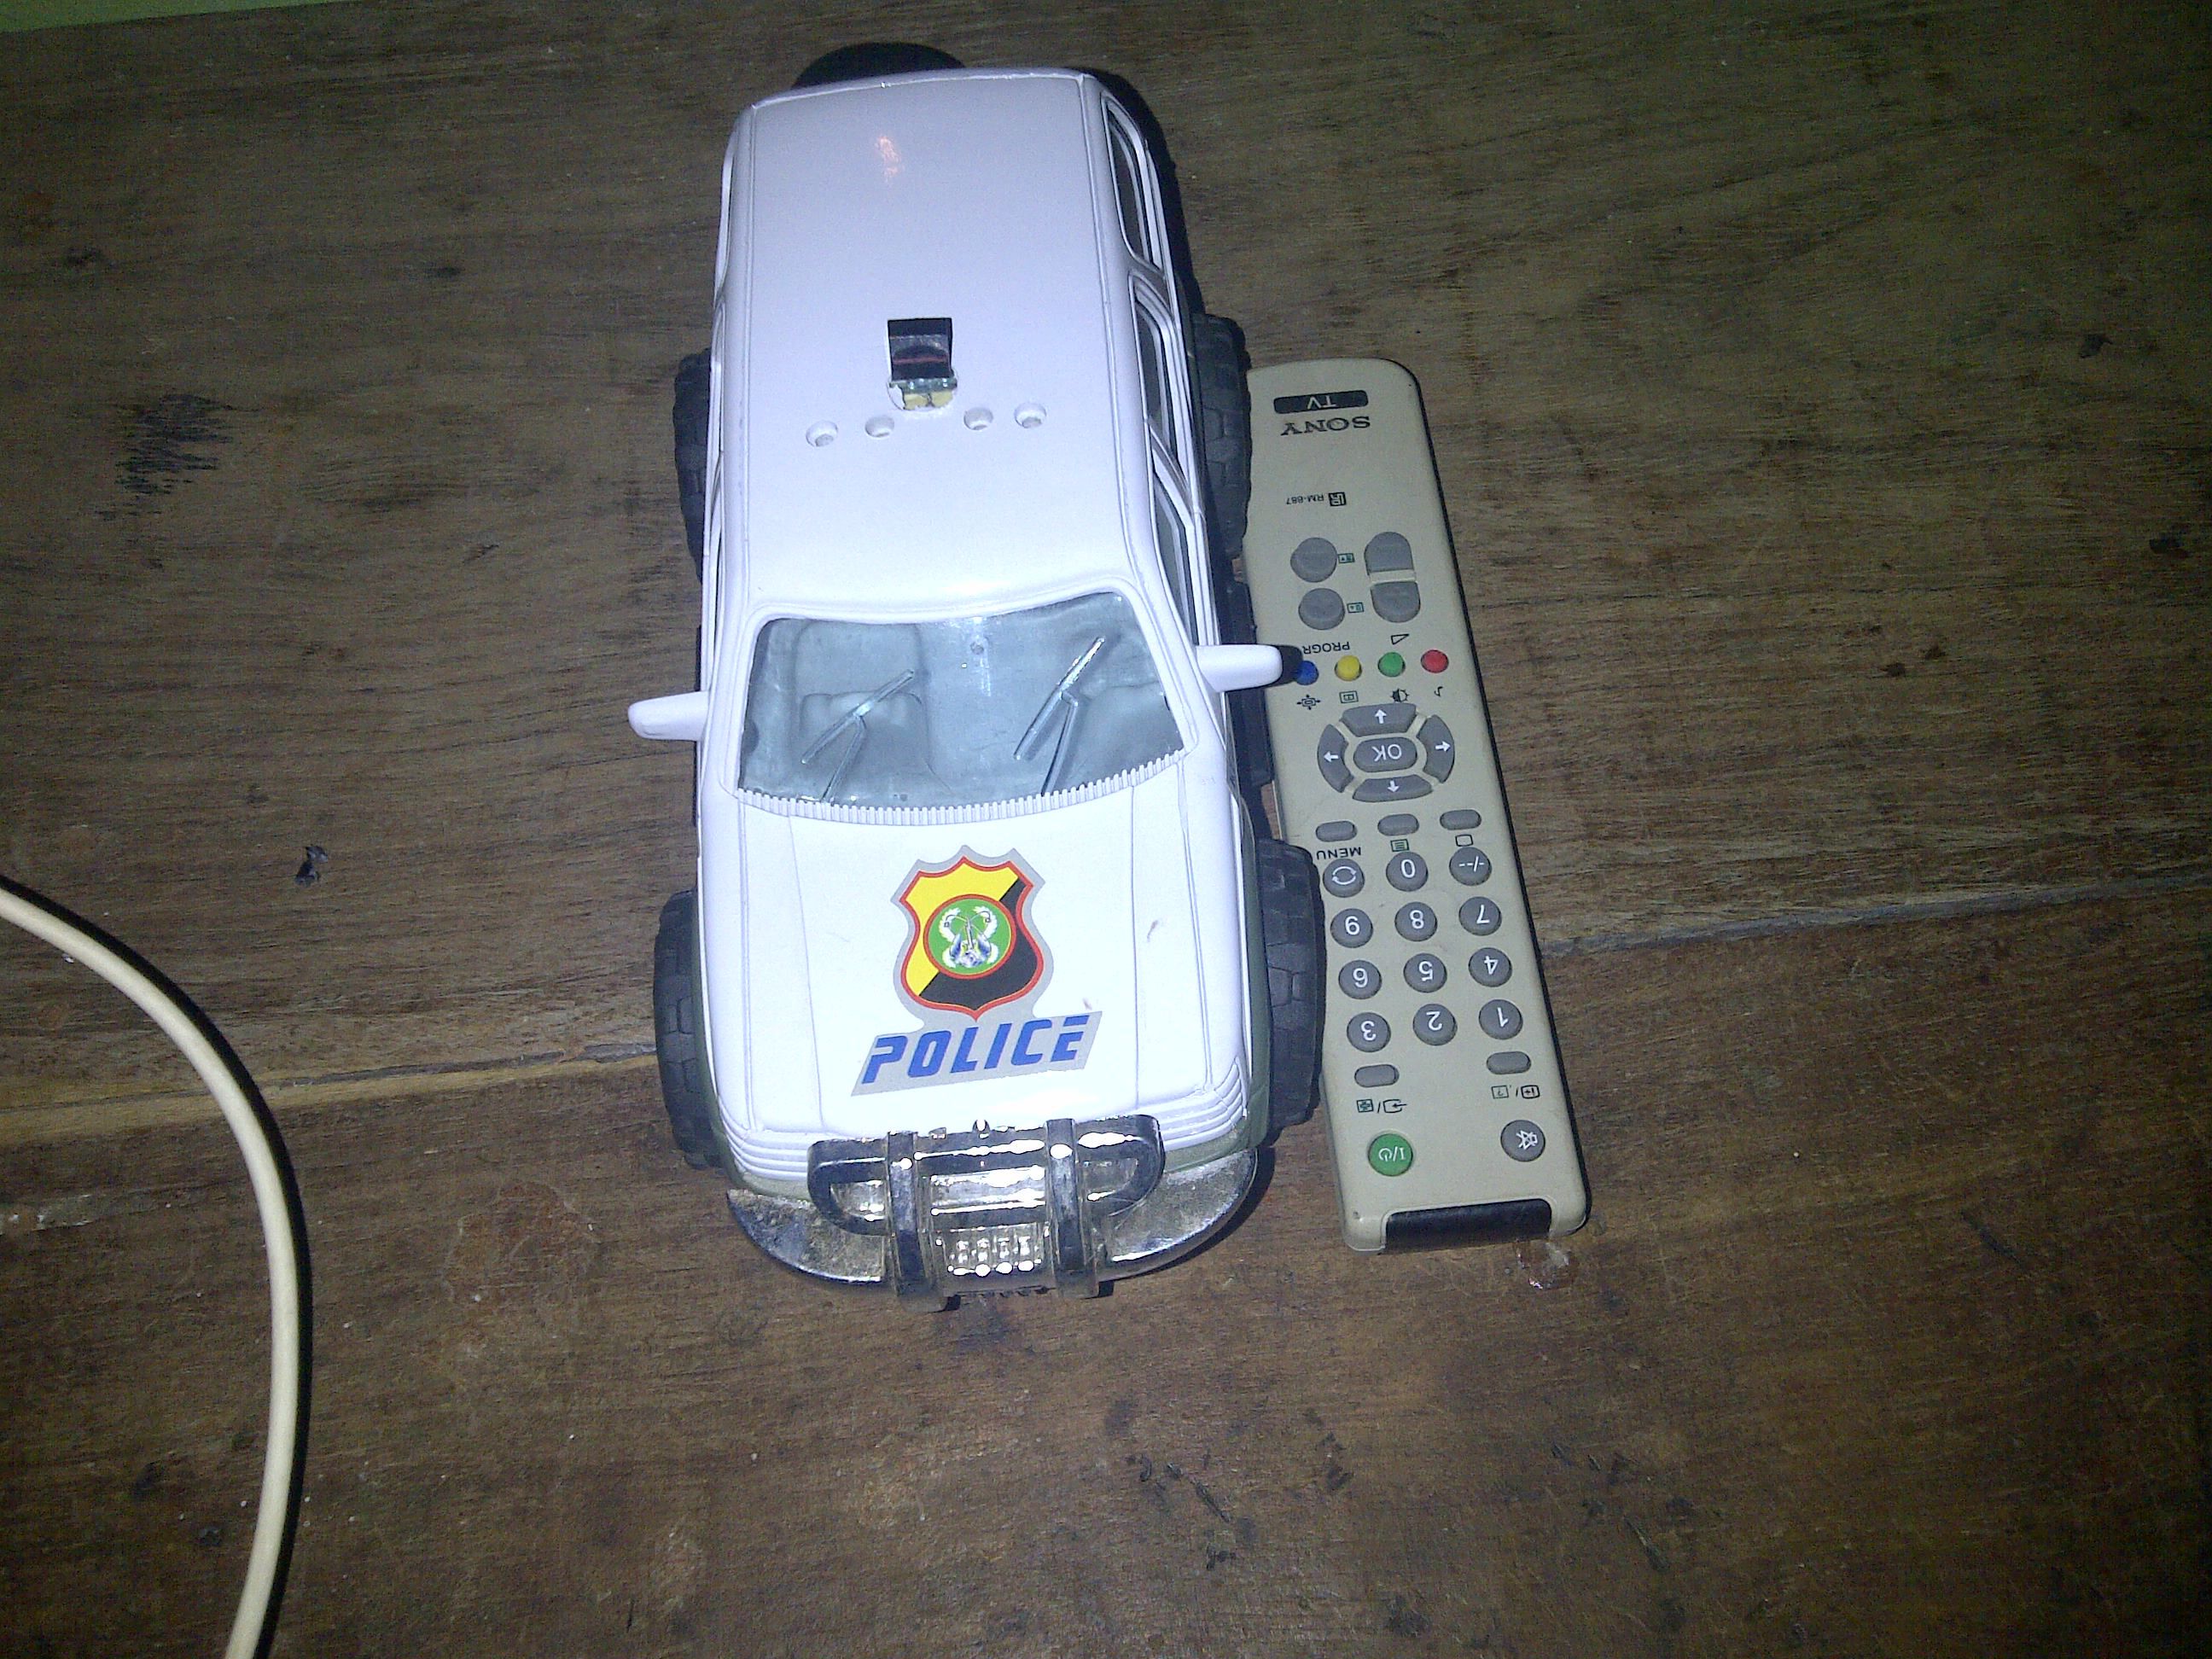
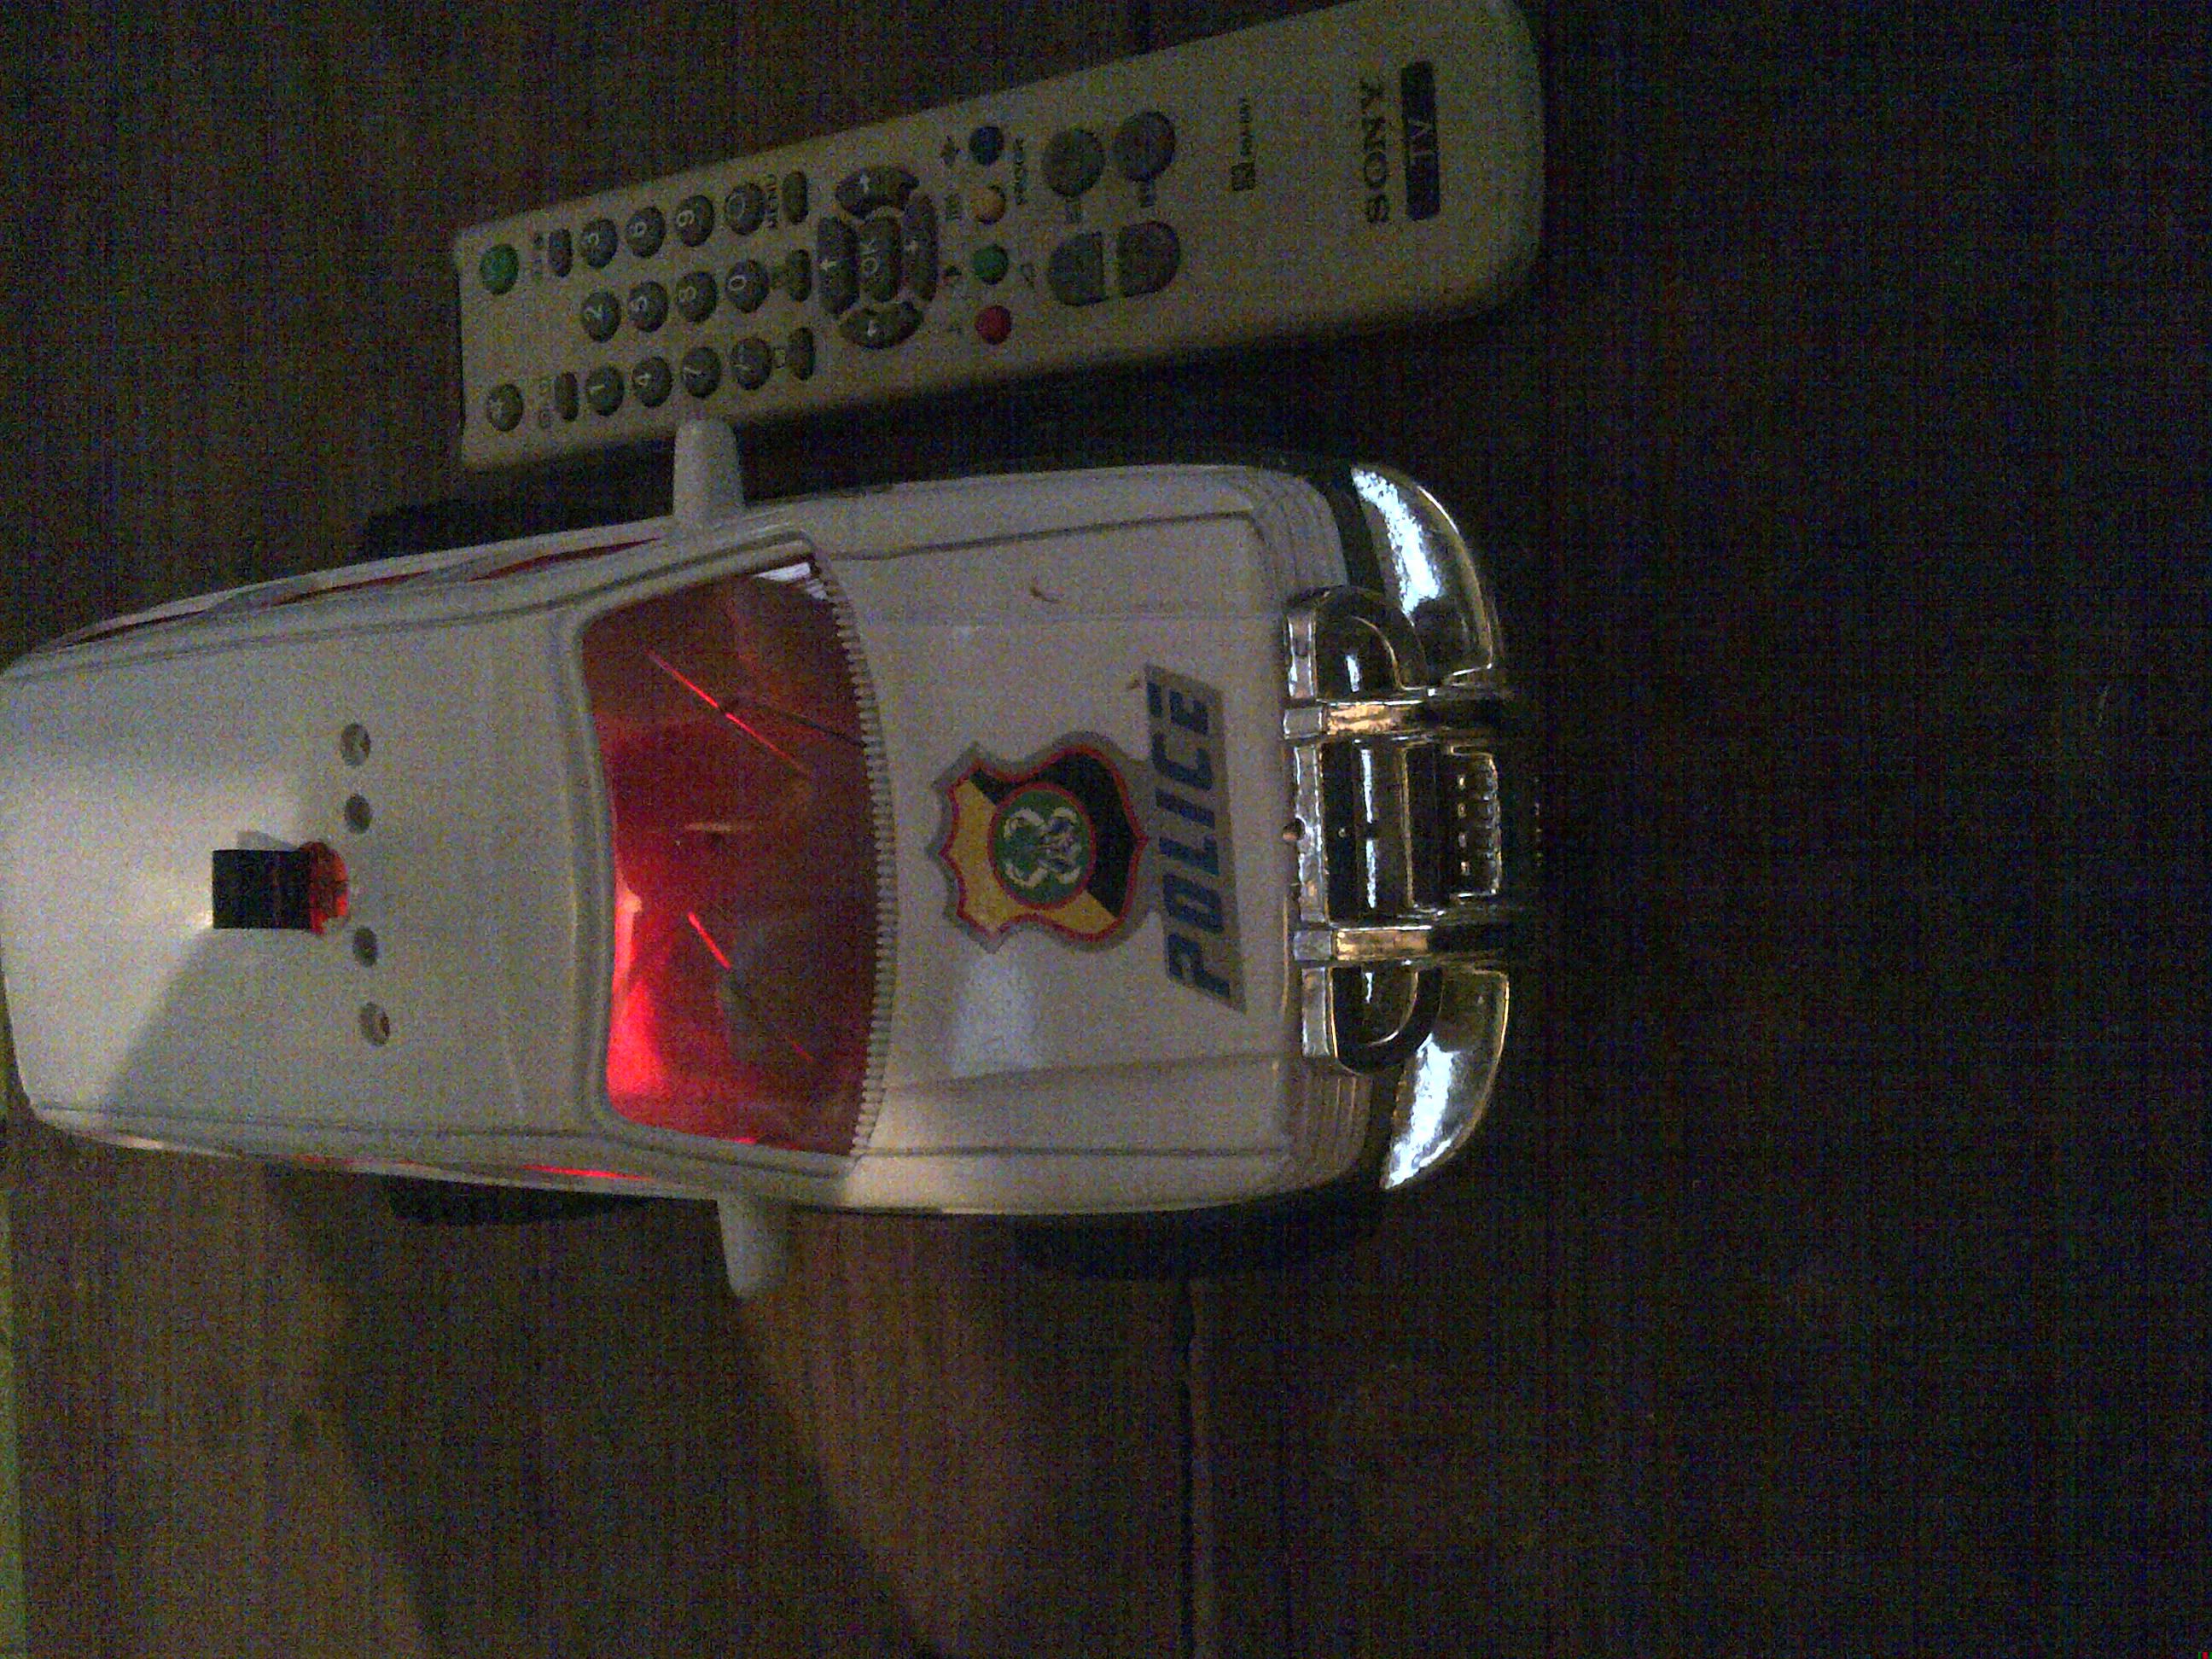
Project Gallery
Actual project photographs and technical images.