
Project Overview
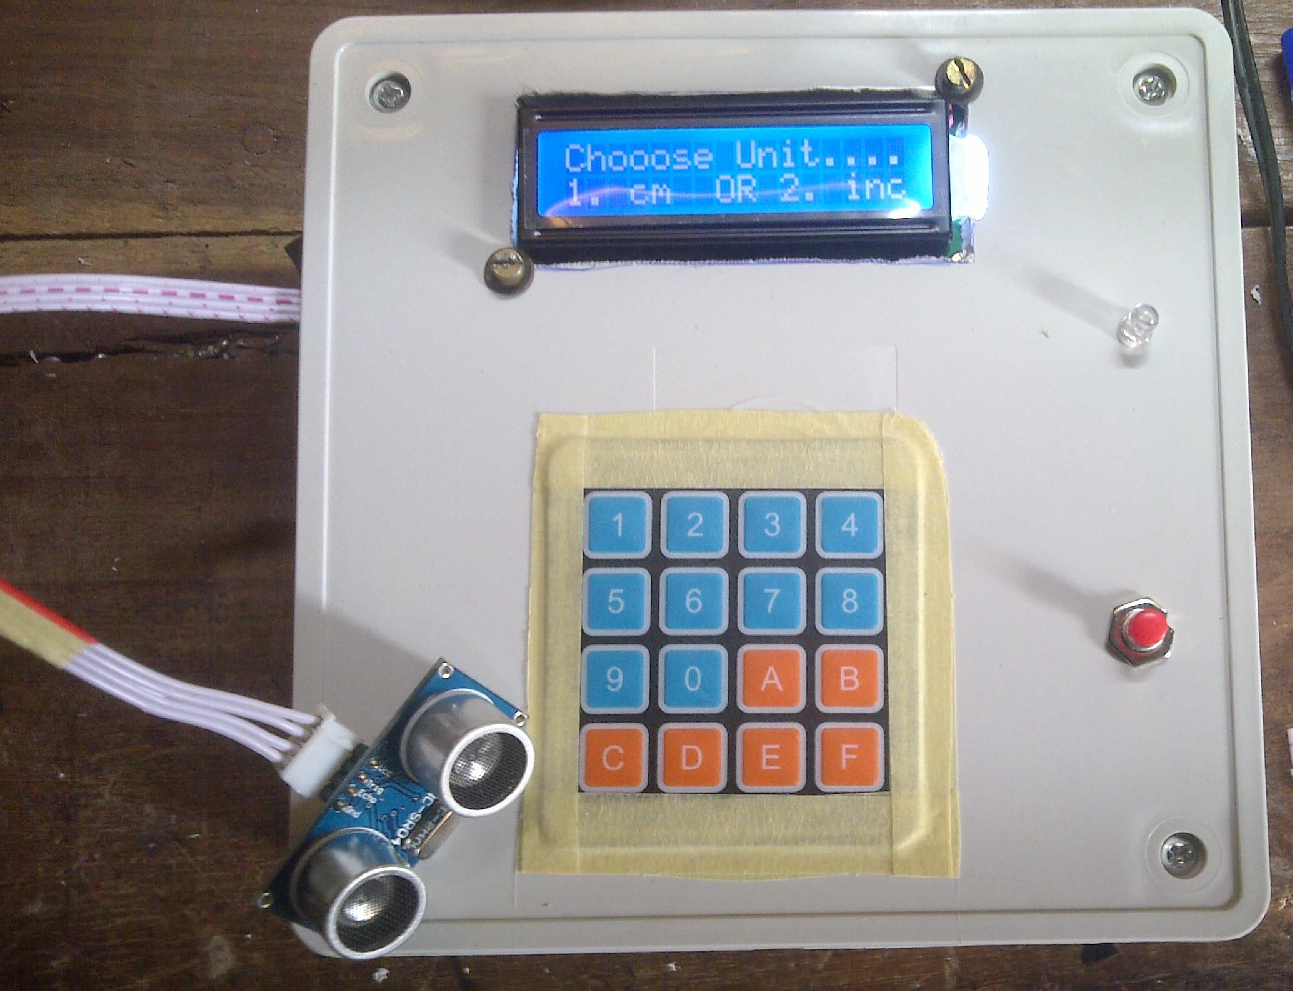
This project demonstrates non-contact object ranging using the HC-SR04 ultrasonic module and a PIC microcontroller.
The documented implementation uses the controller to measure the time associated with the transmitted and returned ultrasonic signal, calculate distance and present the result on an LCD.
How the System Works
- The HC-SR04 transmits an ultrasonic pulse toward the target.
- The returning echo is detected by the ranging module.
- The PIC measures the relevant timing interval and performs the distance calculation.
- The calculated range is displayed on the LCD in the selected unit.
System Architecture
◆HC-SR04Ultrasonic transmit / echo
→
◆PIC16FXXXTiming & calculation
→
◆LCDDistance display
Project Gallery
Actual project photographs and technical images.